Zhuxin Zhang

張祝欣

Zhuxin Zhang

Robotics Researcher

Robot LearningVLA ModelsReinforcement Learning

Currently at PaXini Tech

About Me

My research interests center on how robots can learn reliable manipulation policies from demonstrations and improve them through reinforcement learning. For doctoral research, I am interested in Vision-Language-Action (VLA) models that connect visual perception, geometric reasoning, and long-horizon decision-making, particularly for articulated objects.

I received my M.Eng. in Naval Architecture and Ocean Engineering from Sun Yat-sen University (2026), where I studied reinforcement learning and control for USV path-following and obstacle avoidance. My research addressed disturbances and observation noise, resulting in two published first-author journal articles and two first-author conference papers presented orally at IFAC CAMS 2025. I built a Gymnasium-based simulation platform and led the development of USV and ROS-based AGV prototypes. This work provides a foundation in policy learning, control, simulation, and physical robot testing for my proposed doctoral research.

Education

Sun Yat-sen University
M.Eng. in Naval Architecture and Ocean Engineering
Sep 2023 – Jun 2026
Research on intelligent control and deep reinforcement learning for marine robotic systems.
Shenzhen Technology University
B.Eng. in Automotive Service Engineering
Sep 2019 – Jun 2023

Work Experience

PaXini Tech Shenzhen Co., Ltd.
Embodied AI Data and Algorithm Engineer
Sep 2026 – Present
Collect robot demonstrations for π0.5 post-training and use model inference feedback to iteratively refine the demonstration collection strategy.
Shenzhen Intelligent Magic Cube Robotics Co., Ltd.
VLA Algorithm Engineer
Jul 2026 – Aug 2026
Collected and processed multimodal robot demonstrations for manipulation tasks, supporting the training and evaluation of Vision-Language-Action (VLA) models.
SRED Security & Surveillance Technology Co., Ltd.
ROS Development Engineer (Intern)
Apr 2022 – Jul 2022
Worked on motion-control optimization for autonomous ground vehicles (AGVs) and prepared standardized technical documentation for these systems.

Research Interests

Robot Learning Vision-Language-Action (VLA) Models Reinforcement Learning

Research Background: Marine Robotics & Control

Research Directions

Planned Exploration

Articulation-Aware VLA
How can joint-axis and motion-limit estimates from RGB-D observations guide VLA policies to open doors and drawers without violating articulation constraints?
Research Interest
Articulation-Enhanced World Models
Can articulation-constrained world models predict door and drawer motion under partial occlusion, enabling physically feasible plans for multi-step manipulation?
Research Interest
RL Post-Training for VLA
Can reinforcement learning help demonstration-trained VLA policies recover from grasp failures with limited real-robot trials, while constraining abrupt or unsafe actions?
Research Interest

Publications

Published Papers (6)

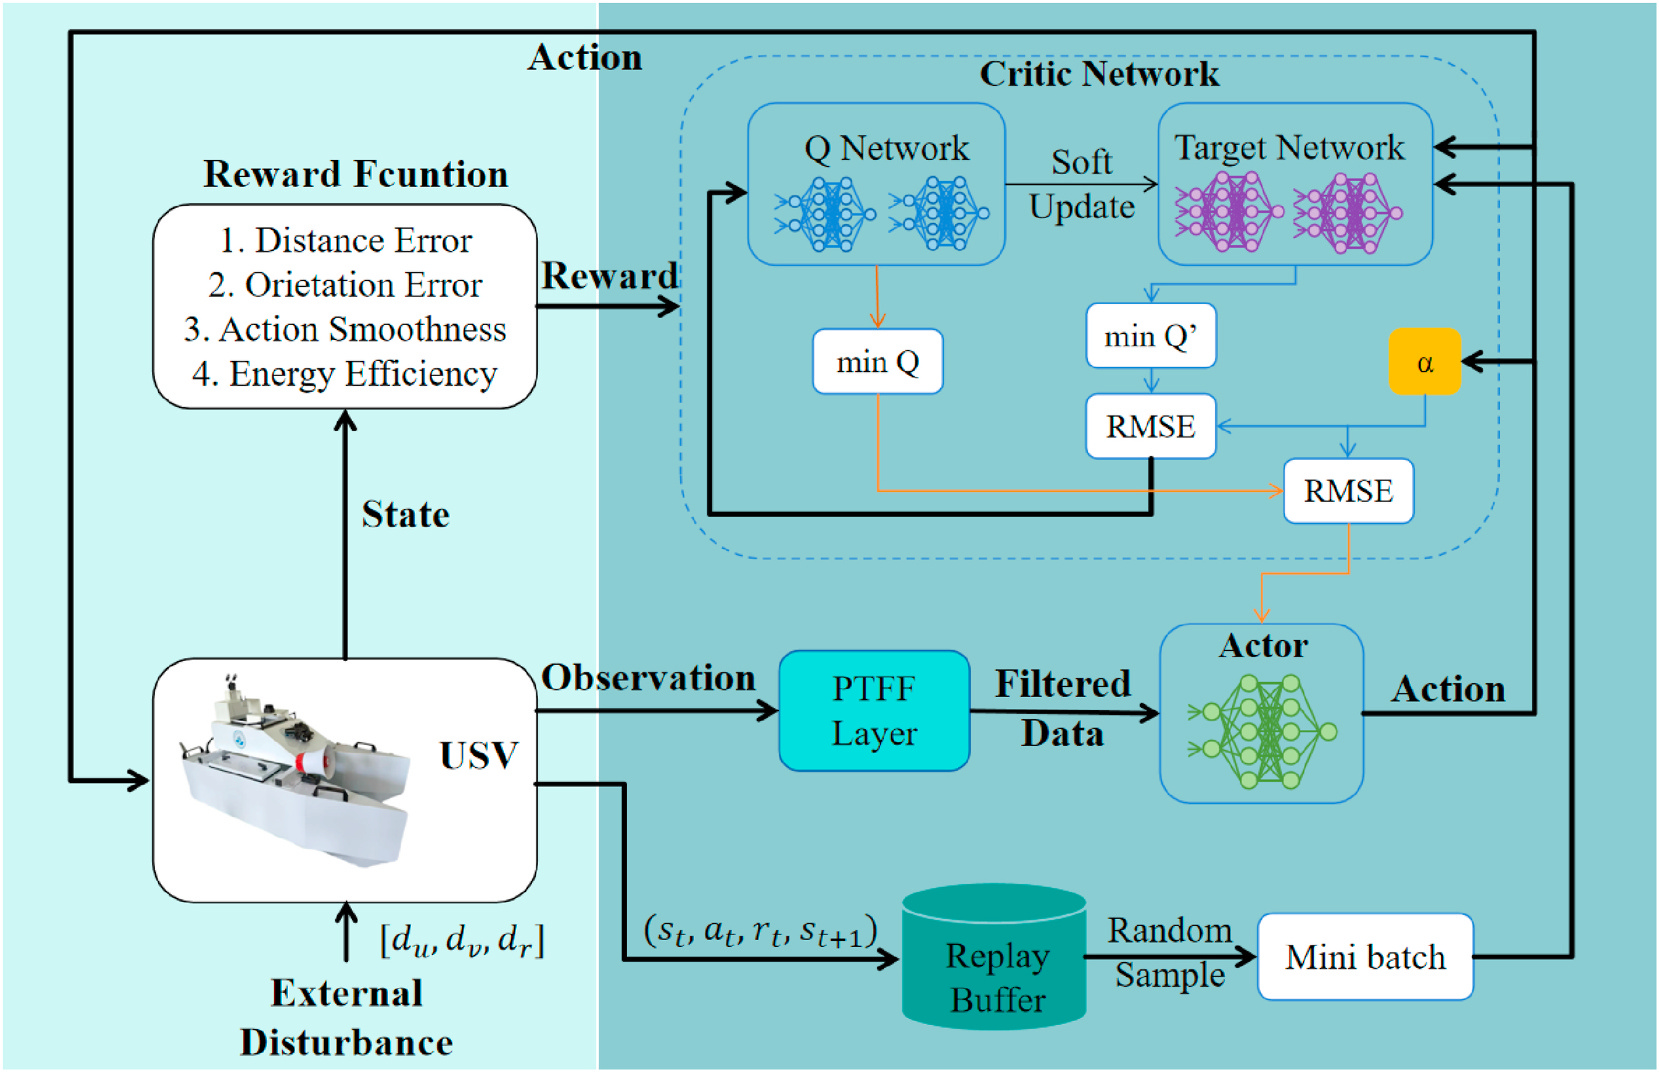
PTFF-enhanced DRL framework linking USV observations, a Fourier filter layer, actor and critic networks, and a replay buffer.
[1]
Improving Control Smoothness in Unmanned Surface Vehicle Path-Following: A Fourier-Enhanced Deep Reinforcement Learning Approach in the Presence of Observation Noises
Zhang, Z., Lu, H., & Miao, J.*
Ocean Engineering, 2025
First Author DOI
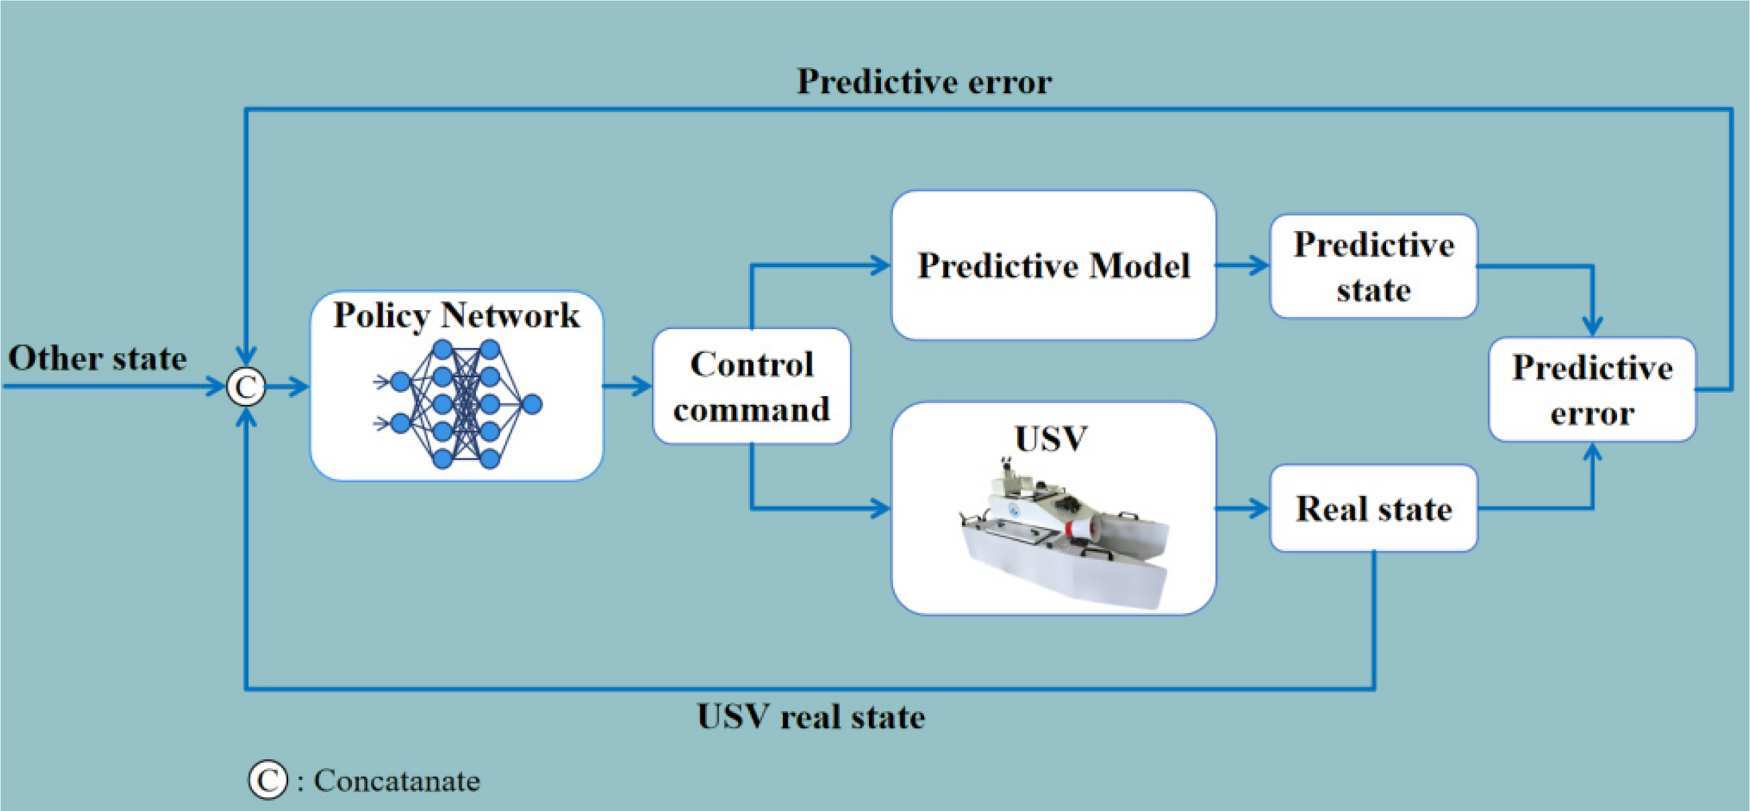
Closed-loop predictive error feedback framework connecting a policy network, predictive model, and real USV states.
[2]
Robust Path-Following Control of Unmanned Surface Vessels Using Deep Reinforcement Learning and Predictive Error Feedback
Zhang, Z., Lu, H., & Miao, J.*
Ships and Offshore Structures, 2026
First Author DOI
[3]
A Novel Robust Adaptive Line-of-Sight Guidance Law for Underactuated Marine Vessels in Complex Disturbance Fields
Lu, H., Zhang, Z., Peng, C.*, Guo, Z.*, Li, Z.
Ocean Engineering, 2026
DOI
[4]
PCLOS Based Fractional-Order Sliding Mode Stochastic Path Following Control for Underactuated Marine Vehicles with Multiple Disturbances and Constraints
Wang, Y., Guo, Y., Zhang, Z., Wang, Z., Miao, J.*, Sun, X.
ISA Transactions, 2024
DOI
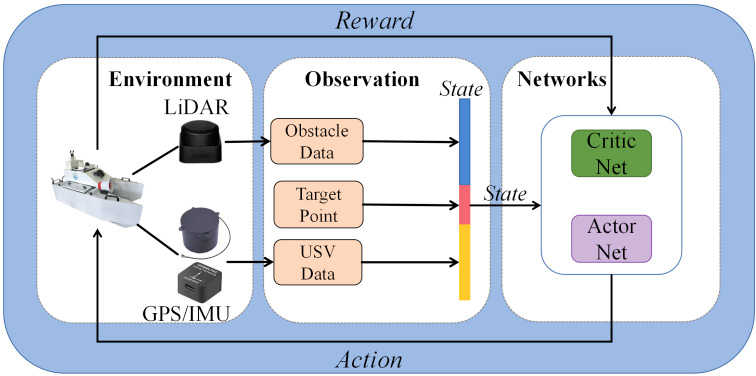
AEOAS obstacle-avoidance framework connecting LiDAR and GPS/IMU observations with actor and critic networks through an action-reward loop.
[5]
AEOAS: SAC with Conservative Q-Learning for USV Obstacle Avoidance in Unknown Marine Environments
Zhang, Z., Li, Z., Wang, Y., Miao, J., Xie, X.*
16th IFAC Conference on Control Applications in Marine Systems, Robotics and Vehicles (CAMS 2025) · IFAC-PapersOnLine, 59(22), 651–656
First Author Oral Presentation DOI
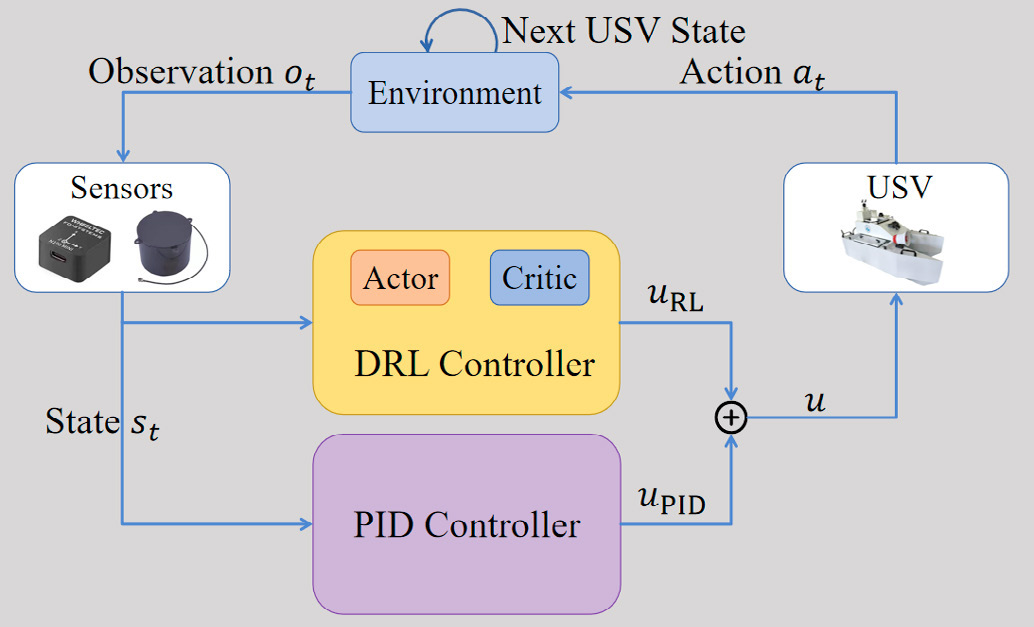
Hybrid USV control framework adding a learned residual action from a DRL controller to the output of a PID controller.
[6]
Residual Reinforcement Learning Integrated PID Control for Robust Path-Following of USVs in Dynamic Environments
Zhang, Z., Li, Z., Wang, Y., Miao, J., Xie, X.*
16th IFAC Conference on Control Applications in Marine Systems, Robotics and Vehicles (CAMS 2025) · IFAC-PapersOnLine, 59(22), 657–662
First Author Oral Presentation DOI

Manuscripts Under Review (2)

[1]
Smooth Path-Following Control of Unmanned Surface Vessels Using Lipschitz-Constrained Deep Reinforcement Learning
Zhang, Z., Lu, H., & Miao, J.*
Manuscript submitted to Ocean Engineering, 2026
Under Review First Author
[2]
Structure-Aware Variable-Gain PID Control for Nonlinear Systems: A Unified Treatment of Conservative and Nonconservative Fields
Lu, H., Zhang, Z., Xiao, P.*, Guo, Z.*
Manuscript submitted to Automatica, 2026
Under Review

Projects

USV Path-Following & Obstacle Avoidance Simulation Platform
Independently built a Gymnasium-based reinforcement learning simulation platform for USV path-following and obstacle avoidance. Integrated multiple DRL algorithms (SAC, PPO, CQL) with realistic marine disturbance models including wind, wave, and current effects.
PythonGymnasiumPyTorchSACCQL
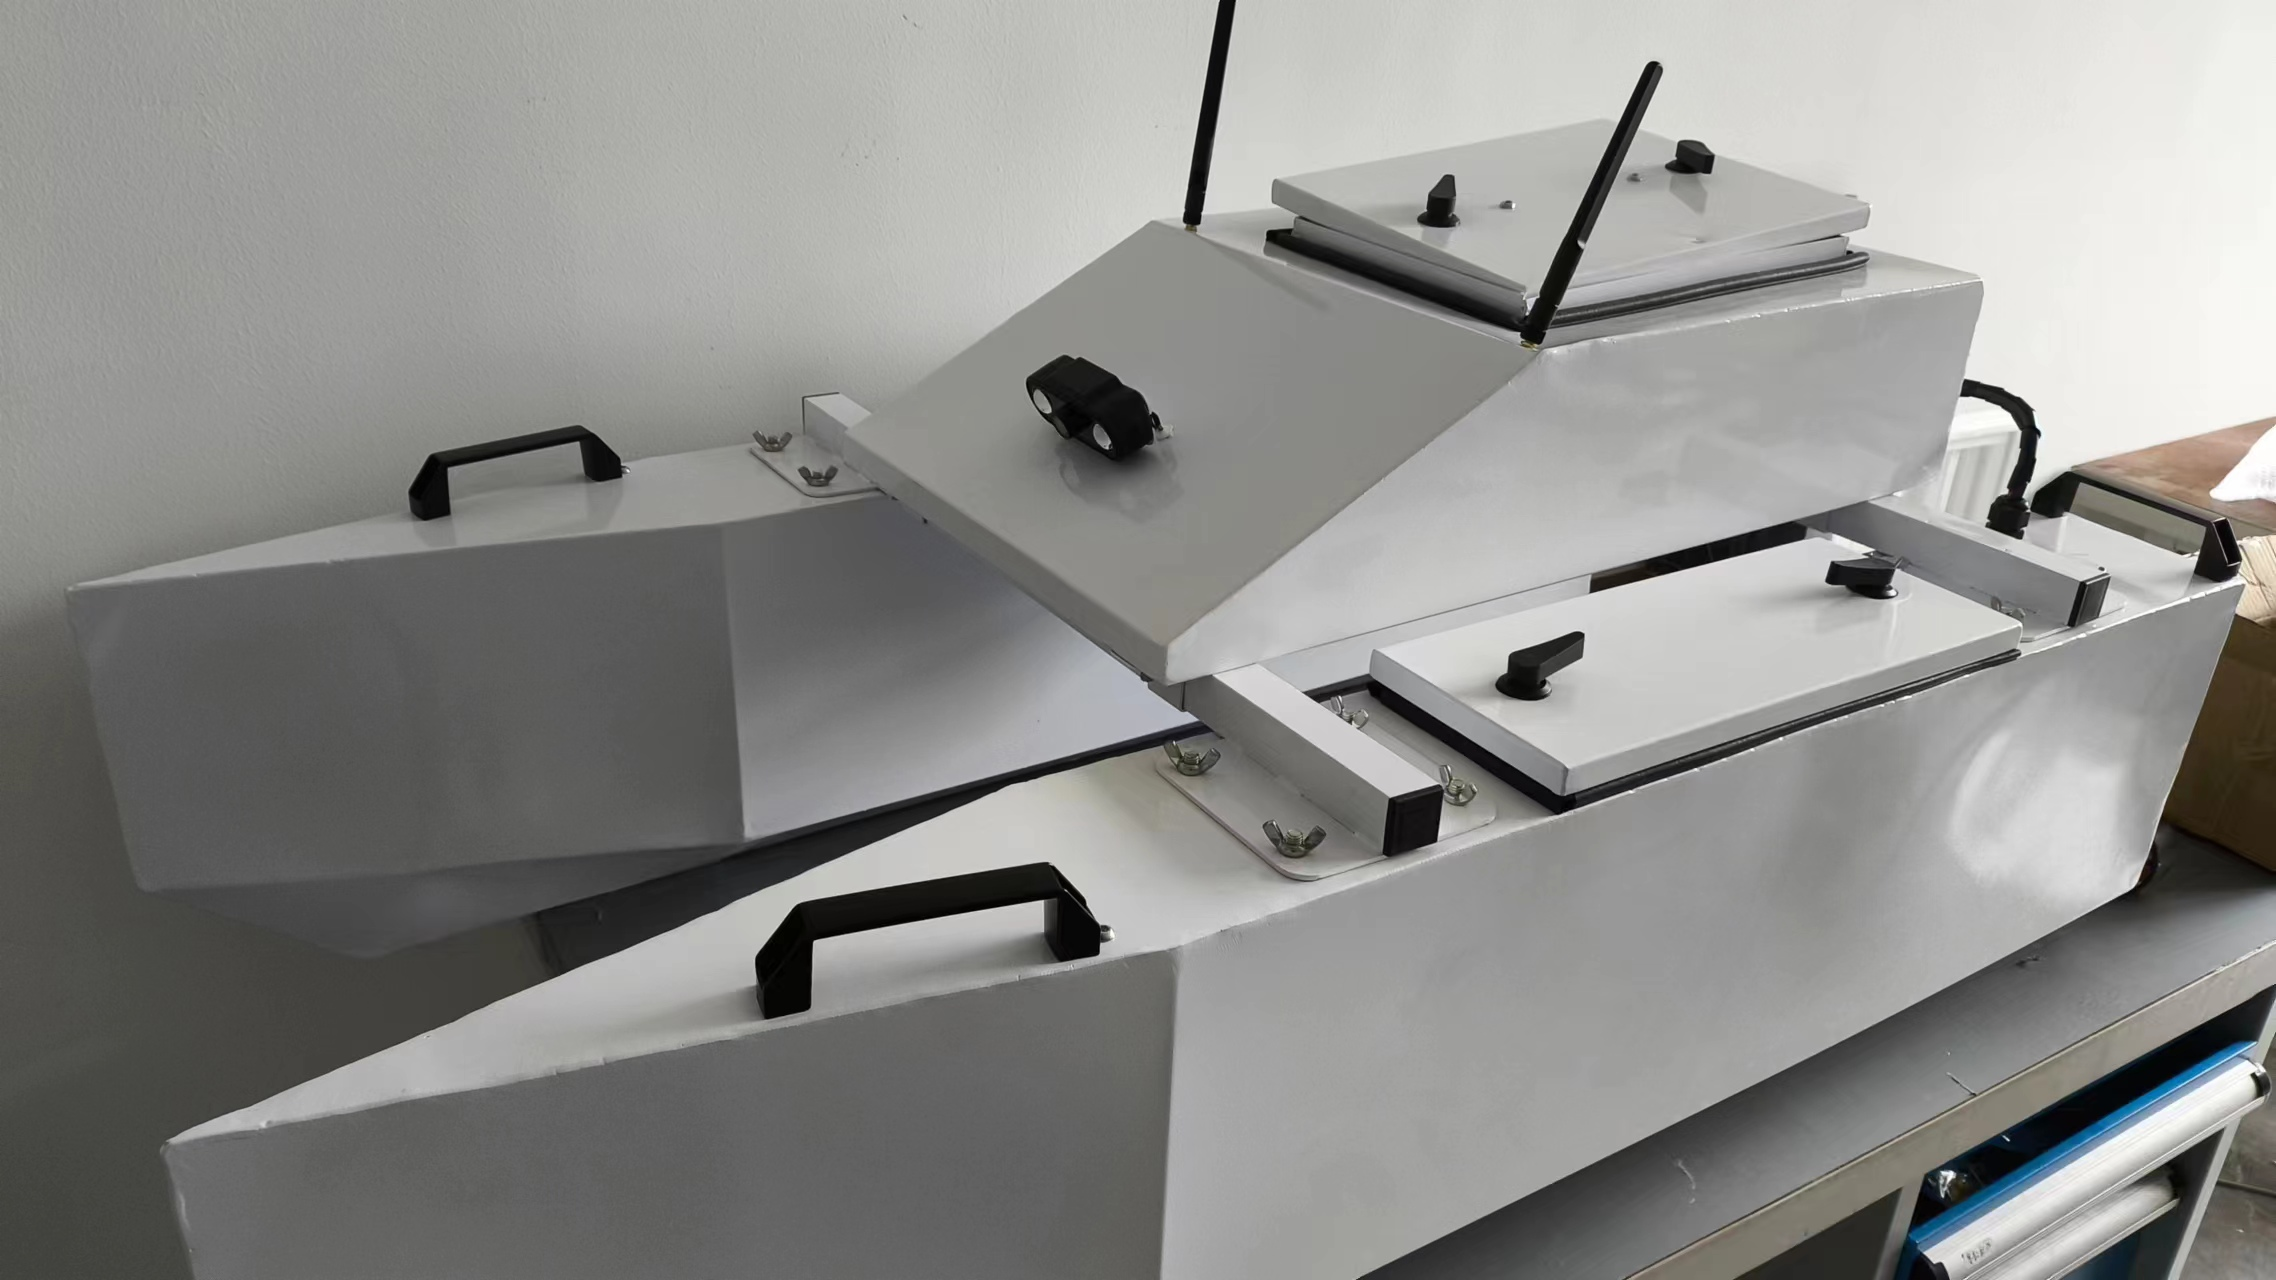
Dual-hull USV prototype with a metallic body, equipment hatches, and antennas.
Dual-Propeller Underactuated USV Prototype
Led a team to develop a physical dual-propeller underactuated USV. Covered the complete workflow from mechanical design and embedded hardware integration to sensor calibration, control algorithm implementation, and real-machine debugging.
C/C++ROSEmbeddedSensor FusionPID
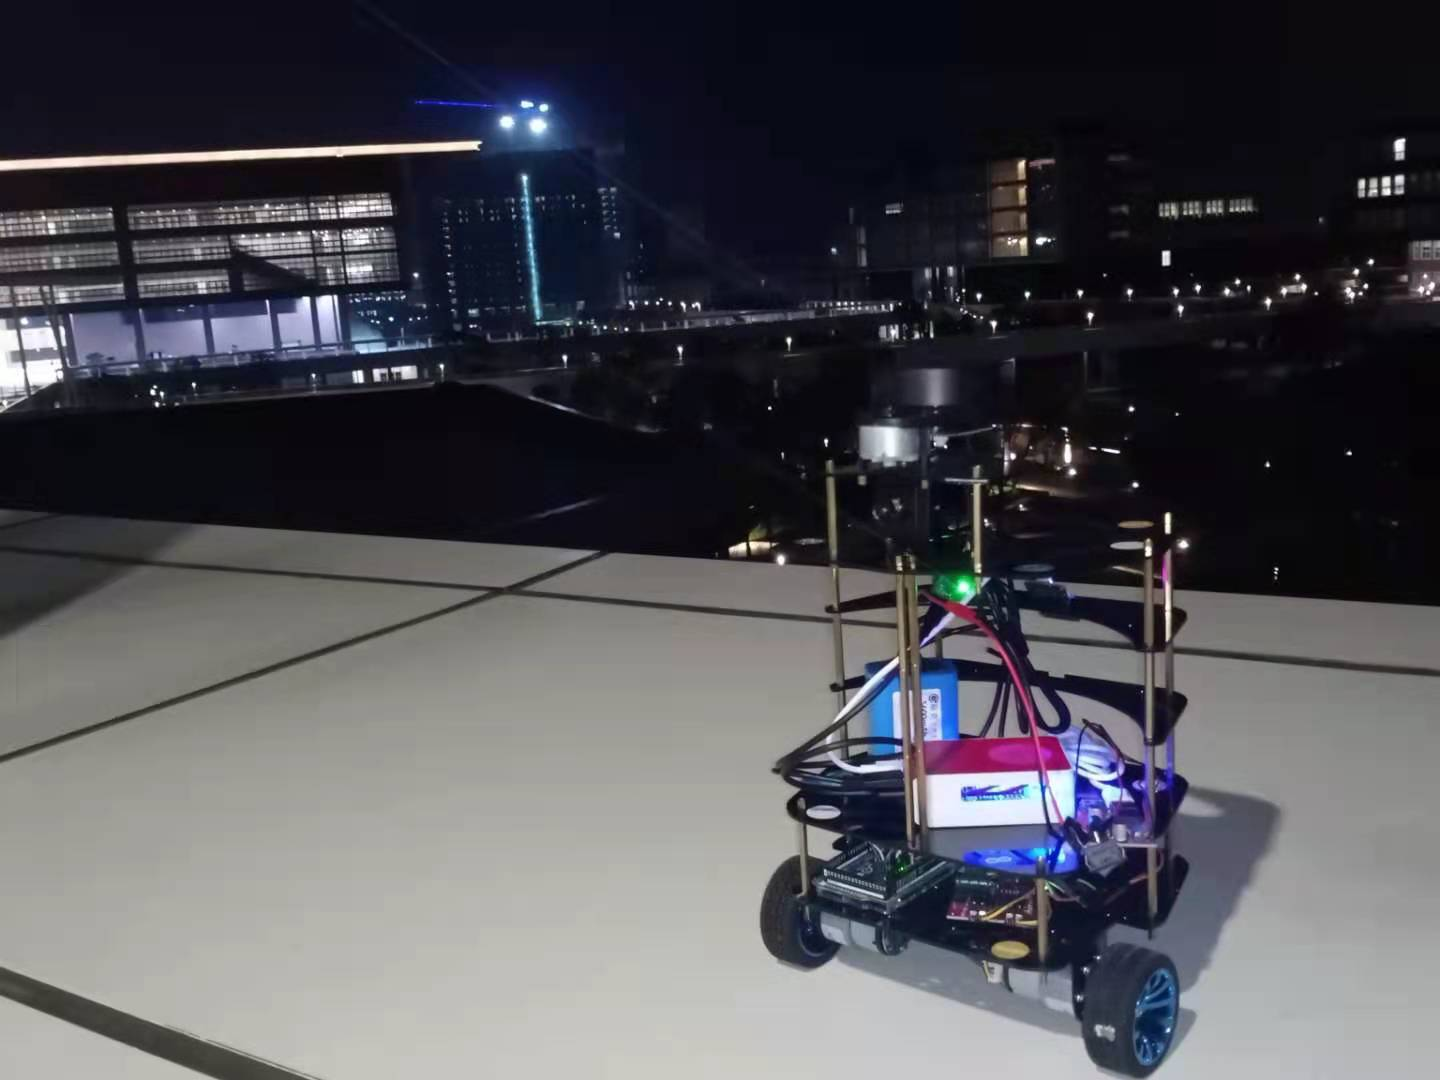
Differential-drive AGV prototype with a layered chassis, onboard electronics, drive wheels, and a top-mounted sensor.
ROS-Based Differential-Drive AGV Prototype
Led development of a ROS-based differential-drive Autonomous Ground Vehicle. Implemented SLAM-based localization, path planning, and real-time motion control. Optimized AGV control performance during internship at a Shenzhen intelligent equipment company.
C/C++ROSSLAMPath PlanningMotion Control

Technical Skills

Programming
Python, C/C++, MATLAB
Learning & Simulation
PyTorch, Gymnasium, PPO, SAC, Simulink
Robotics & Control
ROS/ROS2, robot kinematics, feedback control, sensor calibration
Research Tools
Linux, LaTeX

Awards & Honors

Contact

🏠 From Gaoling, Xi'an, Shaanxi
🎓 B.Eng. — Shenzhen, Guangdong · M.Eng. — Zhuhai, Guangdong
💼 Working in Shenzhen, Guangdong

📧 treeching@163.com